References: Cornel University, https://e.math.cornell.edu>people, Jim Belk - Differential Geometry;
AI Assistant; Personal.
AI Assistant; Personal.
(a)
In[]:=
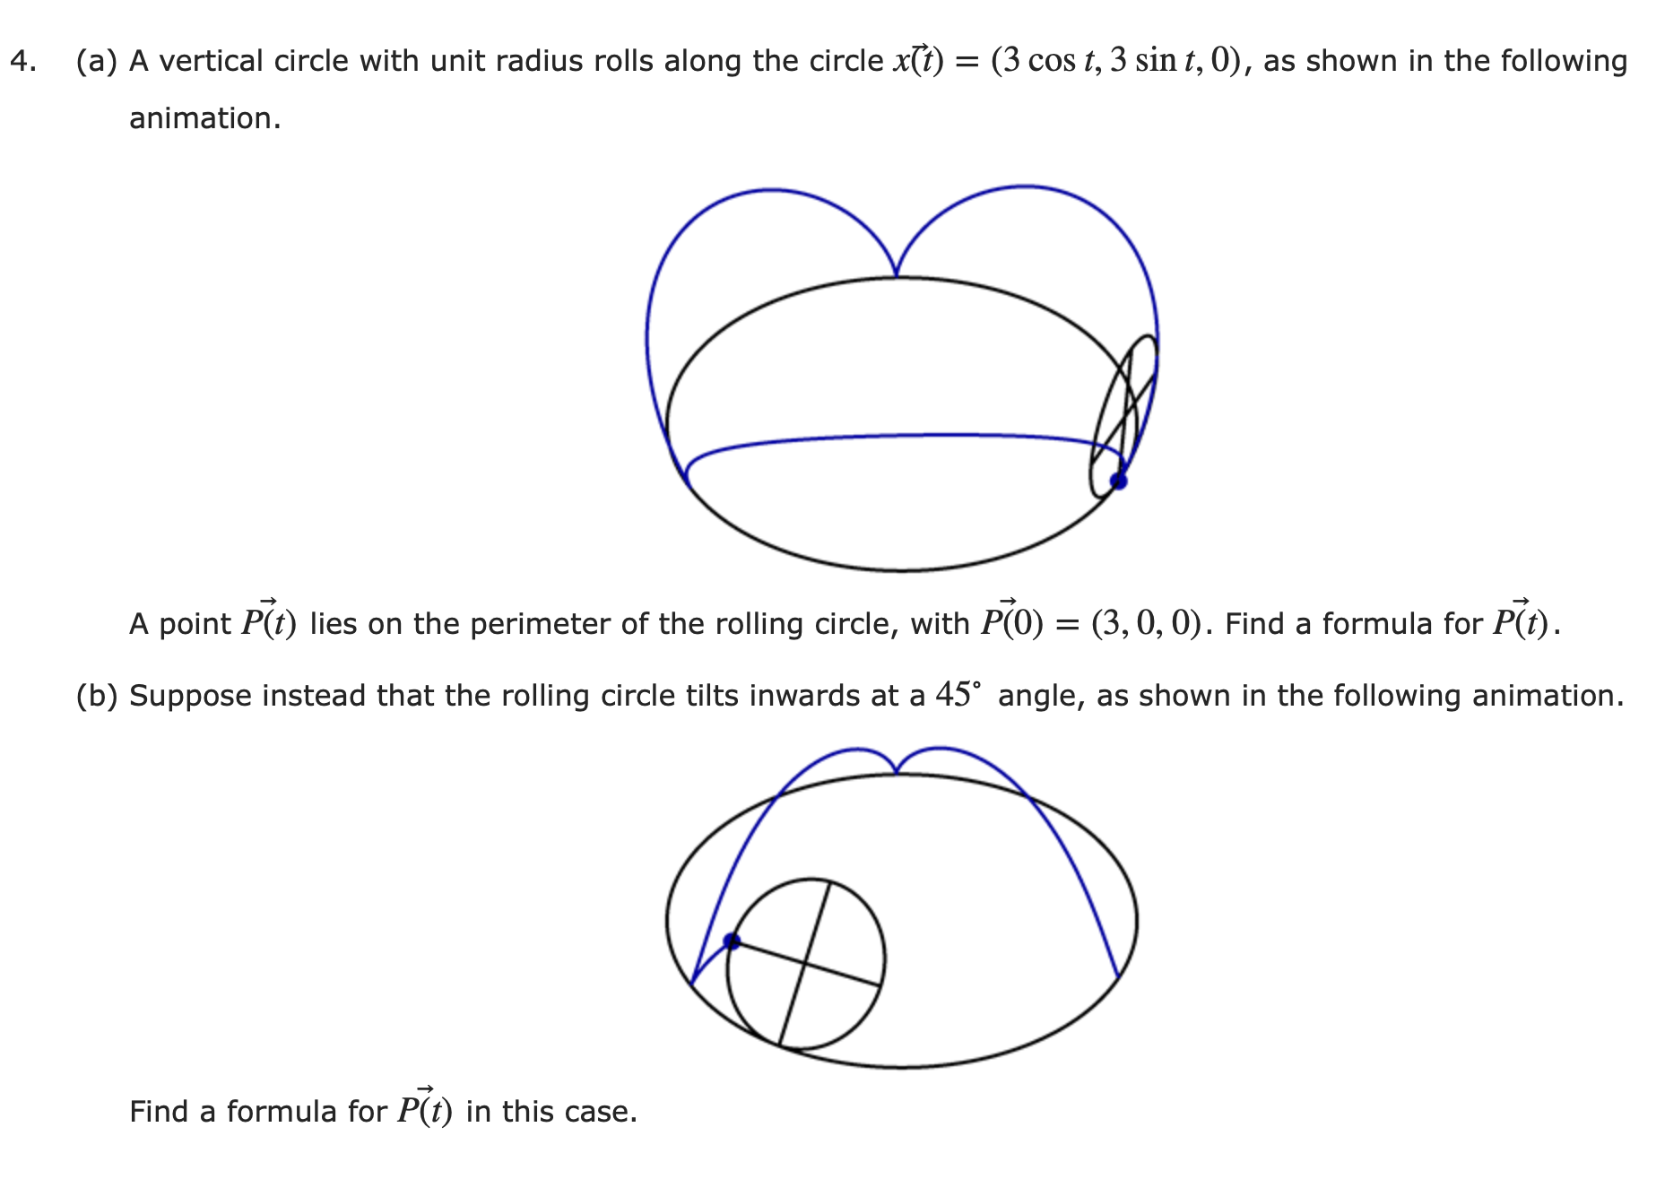
Manipulate[x[t_]:={3Cos[t],3Sin[t],0};tHat[t_]:=Normalize[D[x[s],s]/.s->t];nHat[t_]:=Normalize[{-Cos[t],-Sin[t],0}];zHat={0,0,1};centerB[t_]:=x[t]+zHat;e1[t_]:=zHat;e2[t_]:=tHat[t];e1r[t_]:=Cos[3t]e1[t]+Sin[3t]e2[t];e2r[t_]:=-Sin[3t]e1[t]+Cos[3t]e2[t];wheelB[t_,u_]:=centerB[t]+Cos[u]e1r[t]+Sin[u]e2r[t];pB[t_]:=centerB[t]-e1r[t];Show[ParametricPlot3D[pB[t1],{t1,0,t},PlotStyle->{Blue,Thick}],Graphics3D[{Black,Thick,Line[Table[x[s],{s,0,2π,0.01}]],Black,Thick,Line[Table[wheelB[t,u],{u,0,2π,0.01}]],Black,PointSize[Large],Point[pB[t]],Black,Thick,Line[{centerB[t]-e1r[t],centerB[t]+e1r[t]}],Black,Thick,Line[{centerB[t]-e2r[t],centerB[t]+e2r[t]}]}],Boxed->False,Axes->False,PlotRange->{{-5,5},{-5,5},{-2,2}},ViewPoint->{2,-2,1.5},ImageSize->Large],{t,0.00001,2π}]
Out[]=


(b)
In[]:=
Manipulate[x[t_]:={3Cos[t],3Sin[t],0};tHat[t_]:=Normalize[D[x[s],s]/.s->t];nHat[t_]:=Normalize[{-Cos[t],-Sin[t],0}];zHat={0,0,1};uHat[t_]:=Normalize[nHat[t]+zHat];centerB[t_]:=x[t]+uHat[t];e1[t_]:=uHat[t];e2[t_]:=tHat[t];e1r[t_]:=Cos[3t]e1[t]+Sin[3t]e2[t];e2r[t_]:=-Sin[3t]e1[t]+Cos[3t]e2[t];wheelB[t_,u_]:=centerB[t]+Cos[u]e1r[t]+Sin[u]e2r[t];pB[t_]:=centerB[t]-e1r[t];Show[ParametricPlot3D[pB[t1],{t1,0,t},PlotStyle->{Blue,Thick}],Graphics3D[{Black,Thick,Line[Table[x[s],{s,0,2π,0.01}]],Black,Thick,Line[Table[wheelB[t,u],{u,0,2π,0.01}]],Black,PointSize[Large],Point[pB[t]],Black,Thick,Line[{centerB[t]-e1r[t],centerB[t]+e1r[t]}],Black,Thick,Line[{centerB[t]-e2r[t],centerB[t]+e2r[t]}]}],Boxed->False,Axes->False,PlotRange->{{-5,5},{-5,5},{-2,2}},ViewPoint->{2,-2,1.5},ImageSize->Large],{t,0.00001,2π}]
Out[]=
