ConchoidSurface::usage="The definition of a conchoid surface is:[u, v] = r[u, v] ± k , P is the pole, k distance and r[u, v] the base surface.In this notebook we will obtain the conchoid surface of the sphere {Cos[u]Cos[v] + 1.25, Sin[u]Cos[v], Sin[v]} with the distance k = 1.5 and as pole P the origin.Reference: Peternell, M. et al.Conchoid surfaces of rational ruled surfaces. Vienna University of Technology; Personal. ";
r
c
r[u,v]-P
r[u,v]-P
Graph:
In[]:=
SwatchLegend[{Orange,Blue,Yellow},{"Positive conchoid surface","Negative conchoid surface","Base surface"}]Showr[u_,v_]:={Cos[u]Cos[v]+1.25,Sin[u]Cos[v],Sin[v]};k=1.5;P={0,0,0};r1[u_,v_]:=r[u,v]+k;r2[u_,v_]:=r[u,v]-k;{ParametricPlot3D[{r1[u,v],r2[u,v]},{u,0,2π},{v,0,2π},PerformanceGoal"Quality",PlotPoints60],ParametricPlot3D[r[u,v],{u,0,π},{v,0,2π},MeshFalse,PlotStyle->{Yellow,Opacity[0.6]}]},AxesLabel->(Style[#,15,Blue]&/@{"X","Y","Z"}),AxesOrigin{0,0,0},AxesTrue,BoxedFalse,BoxRatiosAutomatic,PlotLabelStyle[Framed["Conchoid surface of a sphere"],16,Blue,BackgroundYellow],PlotRange{{-1,5},{-5,5},{-2,3}},ViewPoint{-2,-2.4,0.3},ImageSize900
r[u,v]-P
Norm[r[u,v]-P]
r[u,v]-P
Norm[r[u,v]-P]
Out[]=


Out[]=

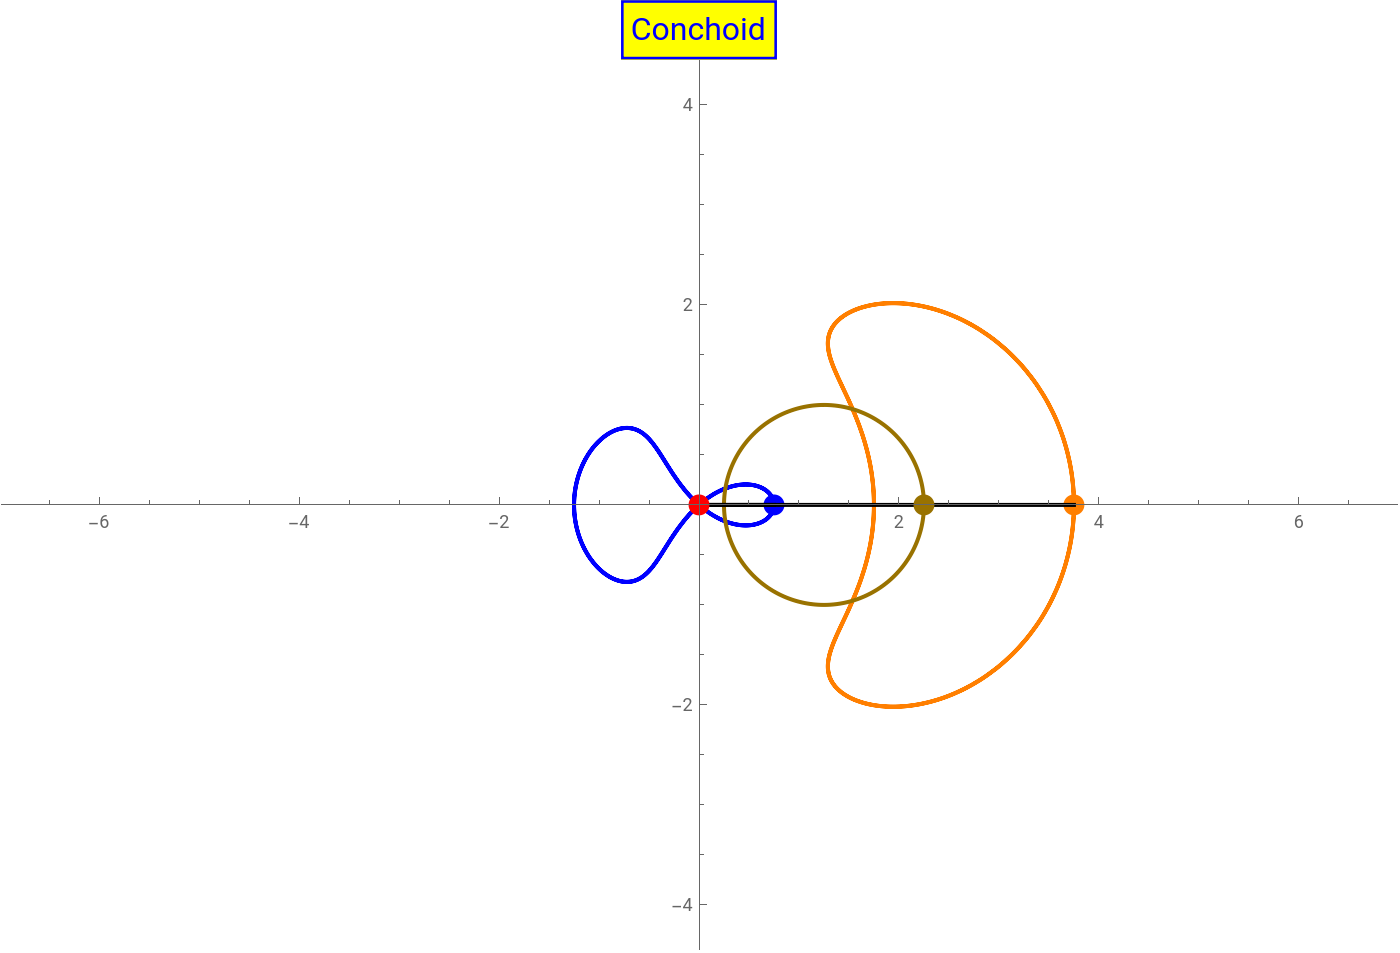
Explanation in 2D:
In[]:=
SwatchLegend[{Orange,Blue,DarkYellow,Red,Black},{"Positive Conchoid","Negative Conchoid","Original function","Pole","Generatrix line"}]Manipulatef[t_]:=Cos[t]+1.25;g[t_]:=Sin[t];=0;=0;k=1.5;[t_]:=f[t]++,g[t]++;[t_]:=f[t]-+,g[t]-+;Show[{ParametricPlot[[t],{t,-2π,t1},PlotStyle{Orange,Thick},PerformanceGoal->"Quality"],ParametricPlot[[t],{t,-2π,t1},PlotStyle{Blue,Thick},PerformanceGoal->"Quality"],ParametricPlot[{f[t],g[t]},{t,0,2π},PlotStyle{DarkYellow,Thick}],Graphics[{Orange,PointSize[0.015],Point[[t1]]}],Graphics[{Blue,PointSize[0.015],Point[[t1]]}],Graphics[{Black,Thick,Line[{[t1],{,},[t1]}]}],Graphics[{Red,PointSize[0.015],Point[{,}]}],Graphics[{DarkYellow,PointSize[0.015],Point[{f[t1],g[t1]}]}]},AxesTrue,AxesOrigin{0,0},AspectRatioAutomatic,ImageSize700,PlotRange{{-2π,2π},{-4,4}},PlotLabelStyle[Framed["Conchoid"],16,Blue,BackgroundYellow]],{{t1,-2π+0.00002,"Value (t1)"},-2π+0.00001,2π,0.00001},ControlPlacement->Top
x
0
y
0
ζ
+
k(f[t]-)
x
0
2
(f[t]-)
x
0
2
(g[t]-)
y
0
k(g[t]-)
y
0
2
(f[t]-)
x
0
2
(g[t]-)
y
0
ζ
-
k(f[t]-)
x
0
2
(f[t]-)
x
0
2
(g[t]-)
y
0
k(g[t]-)
y
0
2
(f[t]-)
x
0
2
(g[t]-)
y
0
ζ
+
ζ
-
ζ
+
ζ
-
ζ
-
x
0
y
0
ζ
+
x
0
y
0
Out[]=


Out[]=