Out[]=
Geometria2D`Conicas`
In[]:=
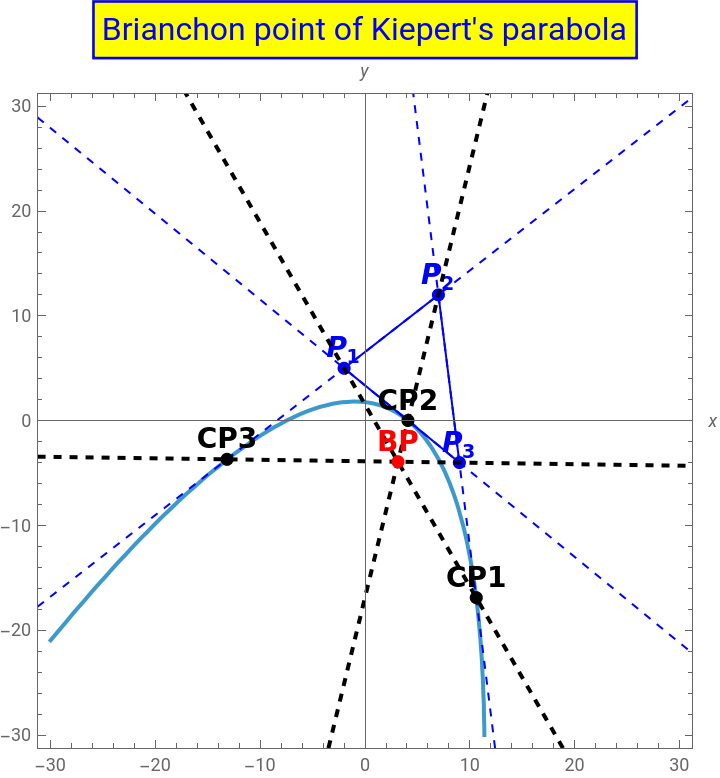
Example 1:
In[]:=
PointOfBrianchon[tri={{-2,5},{7,12},{9,-4}},{-30,30},{-30,30}]
BrianchonPoint X 99 |
{3.13801,-3.91795} |
The values of p and are:
LL´
-3.80159 | 15.2064 |
Axis in x''
After the rotation the equation is:
-70.5524+39.486+6.36862+= 0
´
x
´
y
145853
´2
y
56169
the rotation angle is:
θ = 69.6195°
After the translation the equation is:
39.486+= 0
´´
x
145853
´´2
y
56169
The coordinates of the new origin are:
´´
O
Out[]=
Example 2:
In[]:=
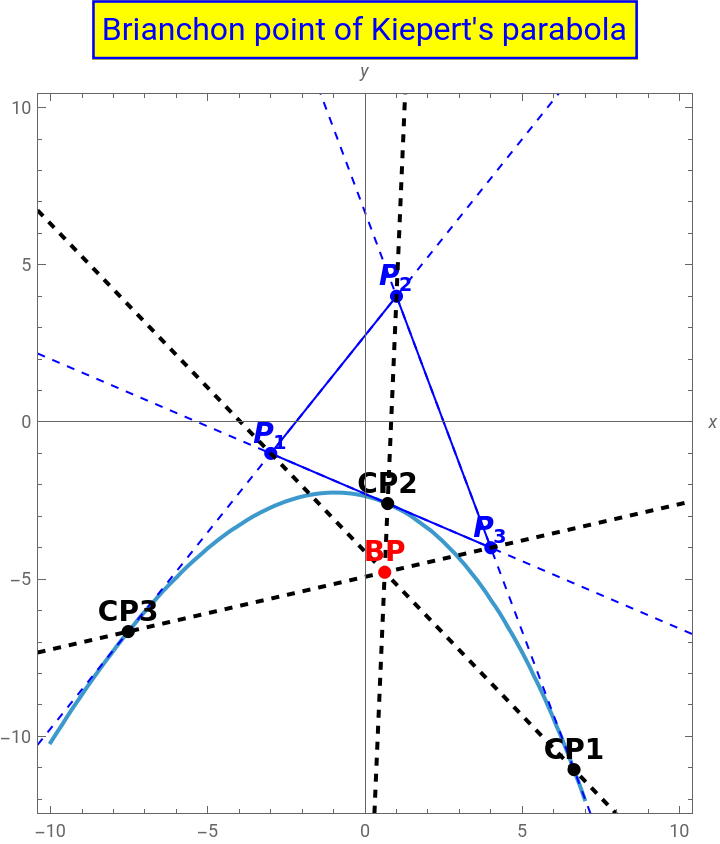
PointOfBrianchon[tri={{-3,-1},{1,4},{4,-4}},{-10,10},{-12,10}]
BrianchonPoint X 99 |
{0.625488,-4.78023} |
The values of p and are:
LL´
-2.05341 | 8.21363 |
Axis in x''
After the rotation the equation is:
10.1842+4.39519-0.252818+= 0
´
x
´
y
21277
´2
y
39762
the rotation angle is:
θ = 83.5985°
After the translation the equation is:
4.39519+= 0
´´
x
21277
´´2
y
39762
The coordinates of the new origin are:
´´
O
Out[]=
Example 3:
In[]:=
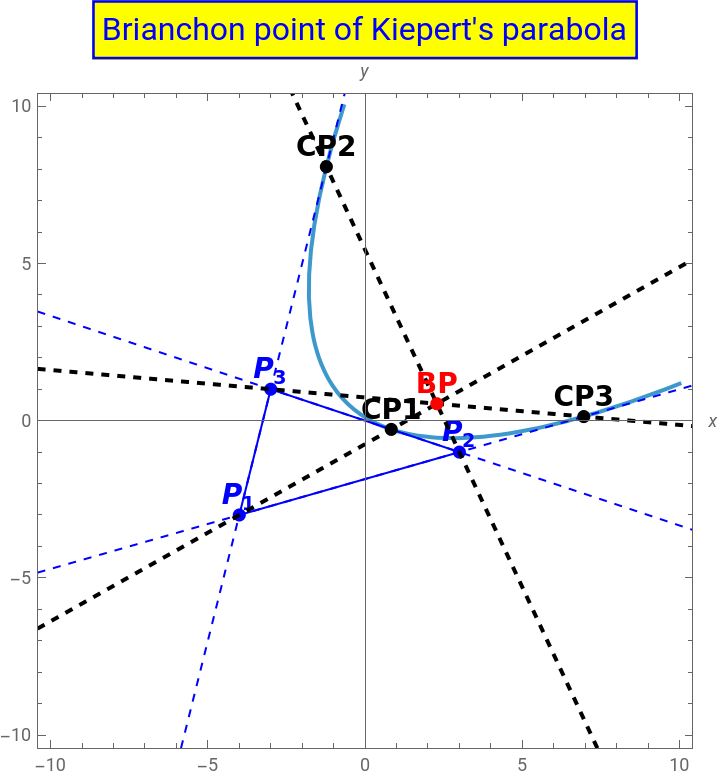
PointOfBrianchon[tri={{-4,-3},{3,-1},{-3,1}},{-10,10},{-10,10}]
BrianchonPoint X 99 |
{2.28285,0.538616} |
The values of p and are:
LL´
1.64743 | 6.58973 |
Axis in x''
After the rotation the equation is:
0.694444-7.28943-1.73604+= 0
´
x
´
y
3365
´2
y
3042
the rotation angle is:
θ = 45.9878°
After the translation the equation is:
-7.28943+= 0
´´
x
3365
´´2
y
3042
The coordinates of the new origin are:
´´
O
Out[]=