Transient Dynamics of a Mercury–Water Differential Manometer with Laminar Viscous Damping
Authors: Housam Binous and Ahmed Bellagi
Transient Dynamics of a Mercury–Water Differential Manometer with Laminar Viscous Damping
Authors: Housam Binous and Ahmed Bellagi
Authors: Housam Binous and Ahmed Bellagi
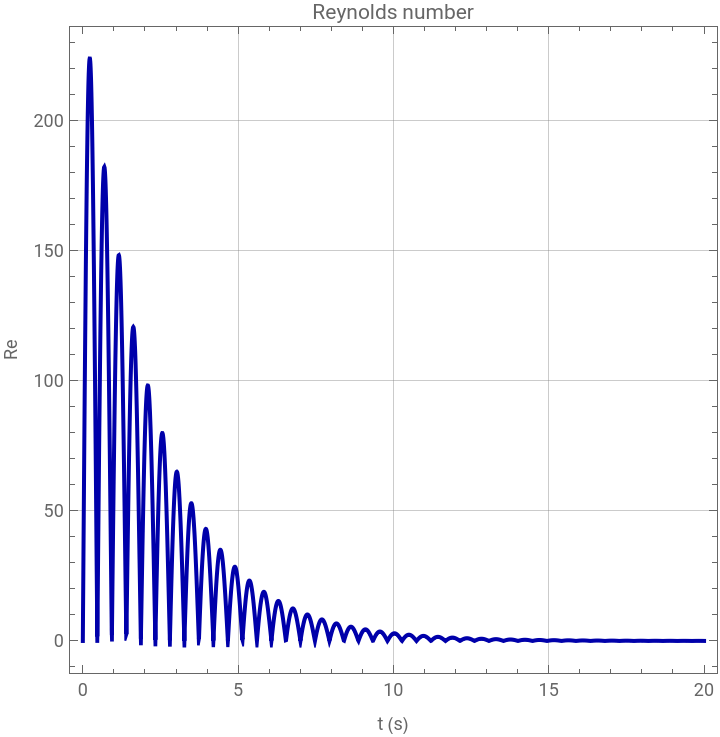
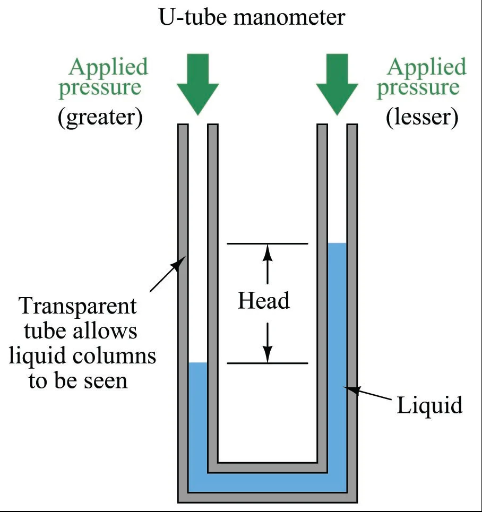
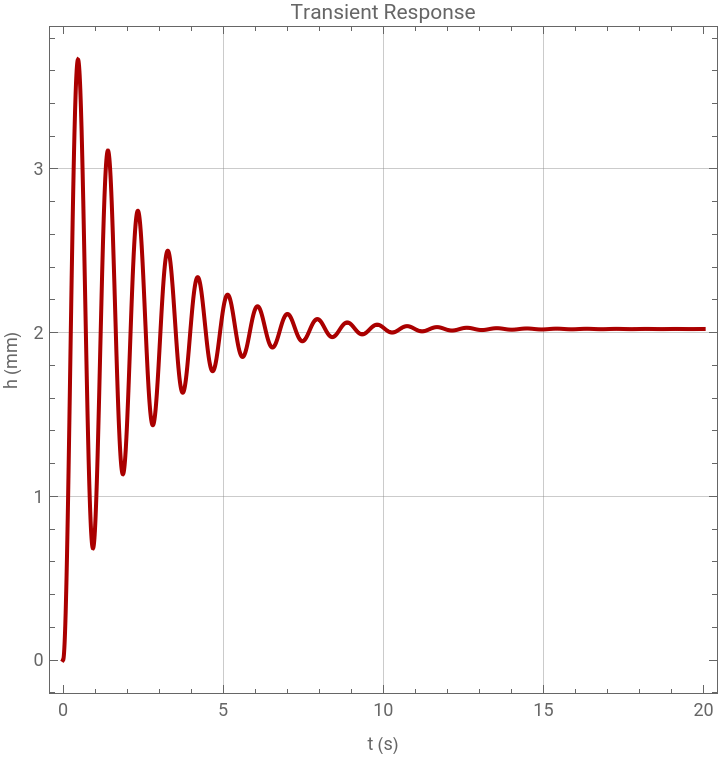
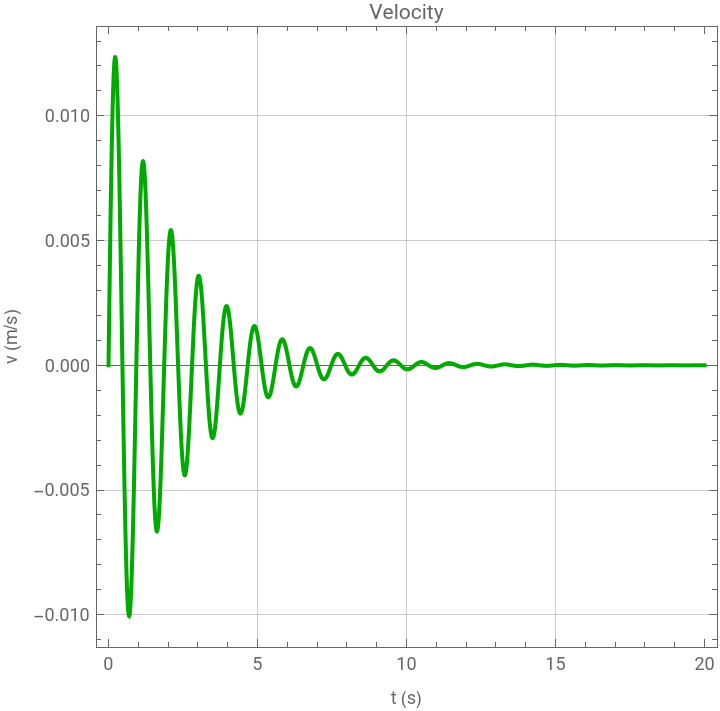
The transient response of a mercury–water differential manometer subjected to a sudden pressure difference is studied. The model accounts for mercury inertia, hydrostatic restoring forces arising from density difference, and laminar regime viscous dissipation. The system behaves as a second-order damped oscillator with a natural frequency and a damping factor equal to 6.741 rad/s and 0.0654 (underdamped - typical for mercury–water manometers (oscillatory)), respectively. We plot the displacement of the mercury interface as well as the velocity versus time. A plot of the Reynolds number indicates that the regime is laminar (Re<2000).
In[]:=
(*fluidsproperties*)rhoM=13600;(*Mercurydensitykg/m^3*)rhoW=1000;(*Waterdensitykg/m^3*)muM=1.5*10^-3;(*MercurydynamicviscosityPa.s*)
In[]:=
g=9.81;(*Gravitym/s^2*)
In[]:=
(*geometry*)R=1*10^-3;(*Tuberadius(m)*)L=0.4;(*Totalmovingmercurylength(m)*)A=PiR^2;(*Cross-sectionalarea*)
In[]:=
tmax=20;
In[]:=
(*Pressurestepinput*)DeltaP0=500;(*PressuredifferenceinPa*)DeltaP[t_]:=DeltaP0UnitStep[t];
In[]:=
(*GoverningODE---Newton'ssecondlawofmotion*)eq=rhoMALh''[t]+(8muMLA/R^2)h'[t]+2(rhoM-rhoW)gAh[t]==ADeltaP[t];
In[]:=
(*Initialconditions*)ics={h[0]==0,h'[0]==0};
In[]:=
(*NumericalsolutionusingNDSolve*)sol=NDSolve[{eq,ics},h,{t,0,tmax}];
In[]:=
(*Displacementofmercuryinterface:h(t)*)Plot[Evaluate[1000h[t]/.sol],{t,0,tmax},FrameLabel->{"t (s)","h (mm)"},PlotLabel->"Transient Response",PlotRange->All,Frame->True,AspectRatio->1,GridLines->Automatic,PlotStyle->Darker@Red]
Out[]=
In[]:=
omegaN=Sqrt[2(rhoM-rhoW)g/(rhoML)];(*Naturalfrequency*)damping=8muM/(rhoMR^2);(*dampingratio*)zeta=damping/(2omegaN);(*lessthan1---underdamped--typicalformercury–watermanometers(oscillatory)*)Print["Natural frequency (rad/s): ",omegaN];Print["Damping ratio: ",zeta];
Natural frequency (rad/s): 6.74117
Damping ratio: 0.0654451
In[]:=
(*velocity:h'(t)*)Plot[Evaluate[h'[t]/.sol],{t,0,tmax},FrameLabel->{"t (s)","v (m/s)"},PlotLabel->"Velocity",PlotRange->All,Frame->True,AspectRatio->1,GridLines->Automatic,PlotStyle->Darker@Green]
Out[]=
In[]:=
(*Reynoldsnumber*)Plot[Evaluate[2RAbs[h'[t]]rhoM/muM/.sol],{t,0,tmax},FrameLabel->{"t (s)","Re"},PlotLabel->"Reynolds number",PlotRange->All,Frame->True,AspectRatio->1,GridLines->Automatic,PlotStyle->Darker@Blue]
Out[]=