Step Response of a Feedback Control System Using a PI Controller
Authors: Housam Binous and Ahmed Bellagi
Step Response of a Feedback Control System Using a PI Controller
Authors: Housam Binous and Ahmed Bellagi
Authors: Housam Binous and Ahmed Bellagi
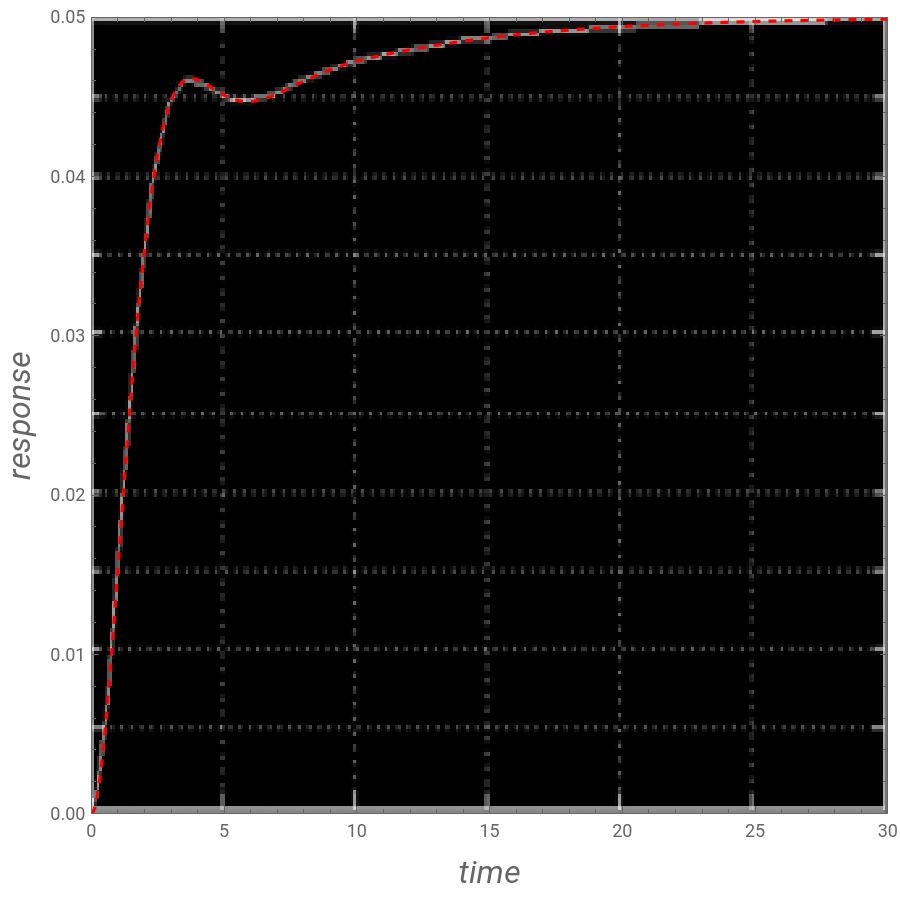
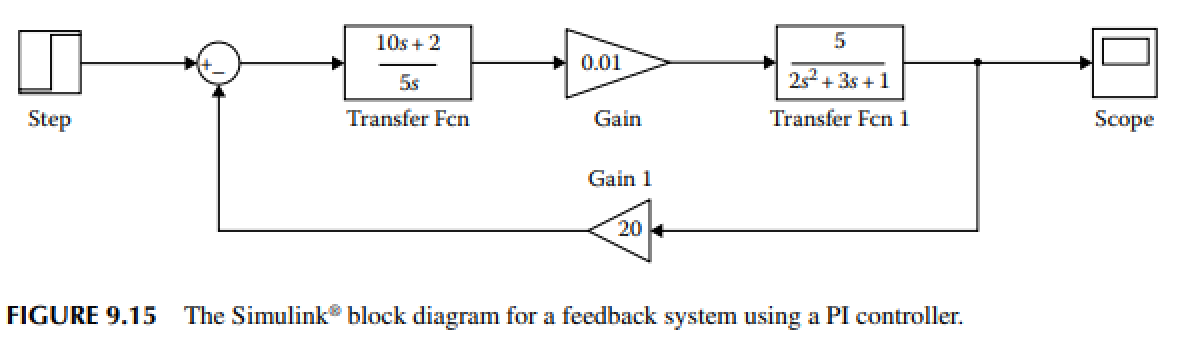
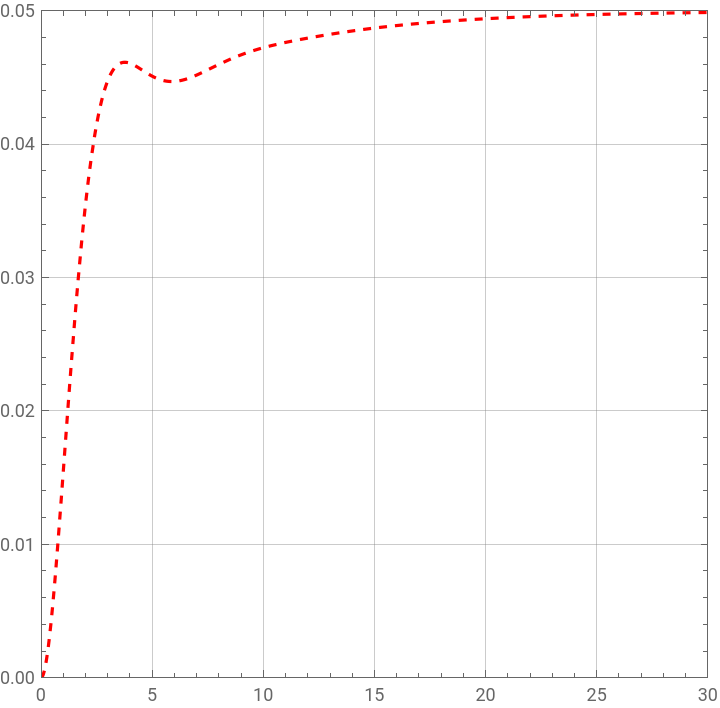
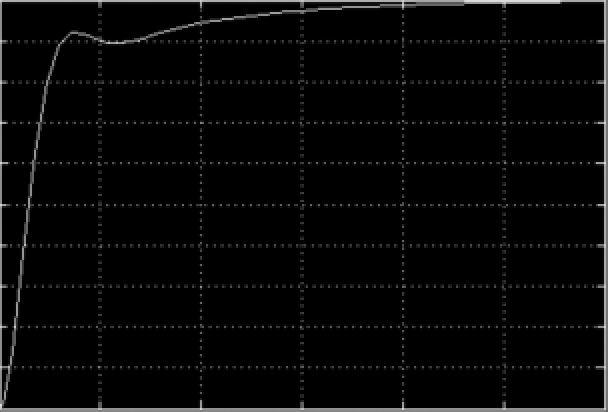
Figure below shows a feedback control system where the process transfer function is Gp(s) = 5/(2 s^2 +3 s + 1) and the proportional–integral (PI) controller is used. This controller transfer function is Gc(s) = 2(1 + 1/(5 s) ). The actuator and the sensor are taken as pure gains. We calculate and plot the closed-loop response to a unit step change in the set-point. Our results are superimposed to their counterparts obtained using SIMULINK and given in Example 9.16 of Ref. 1.References:[1] Yeo, Yeong Koo, Chemical engineering computation with MATLAB, Boca Raton : Taylor & Francis, CRC Press, 2017.
In[]:=
Gp=5/(2s^2+3s+1)
Out[]=
5
1+3s+2
2
s
In[]:=
Gc=Kc(1+1/s/tauI)
Out[]=
Kc1+
1
stauI
In[]:=
Kc=2;tauI=5;
In[]:=
Gs=20;Ga=0.01;
In[]:=
GFBLOOP=GcGpGa/(1+GcGpGaGs)//FullSimplify
Out[]=
0.01+0.05s
0.2+s(1.5+s(1.5+s))
In[]:=
invLP=InverseLaplaceTransform[GFBLOOP1/s,s,t];
In[]:=
p=Plot[invLP,{t,0,30},PlotRange{{0,30},{0,0.05}},FrameTrue,GridLinesAutomatic,AspectRatio1,PlotStyle{Red,Dashed}]
Out[]=
In[]:=
IMG=
;
In[]:=
Show[p,ImageSize450{1,1},Prolog{Raster[ImageData[IMG,DataReversedTrue],{Scaled[{0.0,0.0}],Scaled[{1,1.00}]}]},FrameLabel{Style["time",16,Italic],Style["response",16,Italic]}]
Out[]=