Inspiration
Inspiration
The following video from YouTube struck me as a good use case for FoldPairList.
Functions
Functions
The function fabrikStep performs the translation & rotation on one single leg in the jointed structure. It requires the vector we want transformed and the target point where we want the transformed vector to be rooted. This function will be called by fabrik.
In[]:=
fabrikStep[newroot:{_,_},vector:{r:{_,_},t:{_,_}}]:=With[{len=Norm[t-r]},{new={newroot,newroot+len Normalize[r-newroot]}},{new,Last[new]}]
The function fabrik implements the forward-backward algorithm. To make this a complete implementation, we’d need to add a tolerance and repeat the forward-backward algorithm until the desired tolerance is achieved.
In[]:=
fabrik[path:{{_,_}...},target:{_,_}]:=With[{vecs=Partition[path,2,1]},{pass1=FoldPairList[fabrikStep,target,Reverse@vecs]},Prepend[FoldPairList[fabrikStep,First@path,Reverse@pass1][[All,2]],path[[1]]]]
Demonstration
Demonstration
Trying a few different random starting paths shows multiple passes through the algorithm may be necessary.
With{testPath=AnglePath[Table[{RandomReal[{.5,1.5}],RandomReal[{-Pi/2,Pi/2}]},{4}]],target={.5,.5}},{pass1=fabrik[testPath,target]},{pass2=fabrik[pass1,target]},GraphicsGreen,AbsolutePointSize[10],Point[testPath[[1]]],Red,AbsolutePointSize[10],Point[target],Blue,Arrow[testPath],,Axes->True
Out[]=
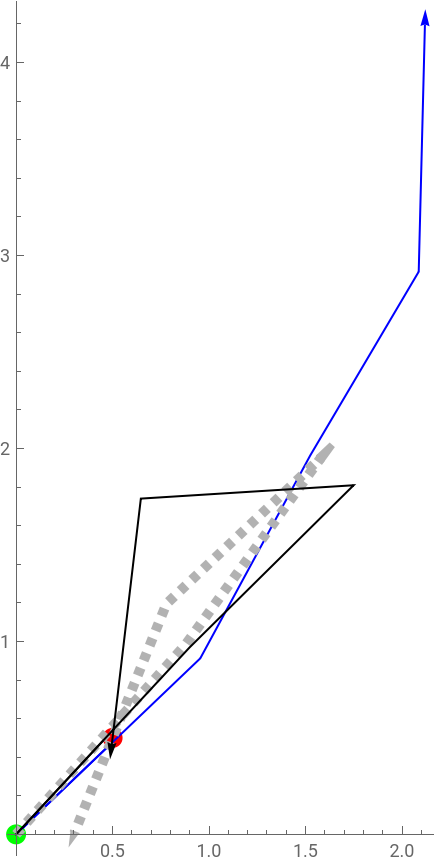
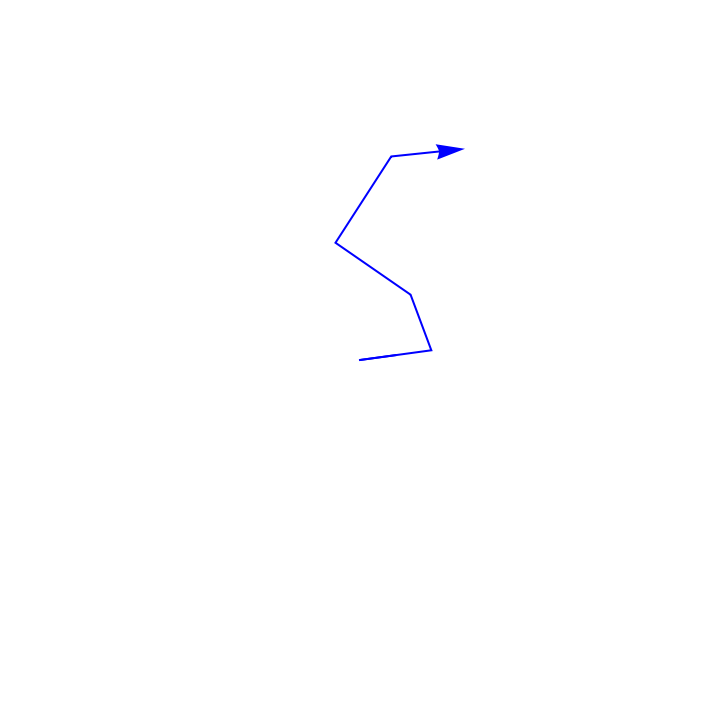
We can watch the segmented structure deform as we pull the endpoint dynamically.
In[]:=
DynamicModule[{path=AnglePath[Table[{RandomReal[{3,10}],RandomReal[{-Pi/2,Pi/2}]},{5}]]},Manipulate[Graphics[{Blue,Arrow[path=fabrik[path,p]]},PlotRange->30],{{p,Last@path},Locator}],SaveDefinitions->True]
Out[]=

CITE THIS NOTEBOOK
CITE THIS NOTEBOOK
Implementing FABRIK with Wolfram: forward and backward reaching inverse kinematics
by Eric Rimbey
Wolfram Community, STAFF PICKS, February 23, 2026
https://community.wolfram.com/groups/-/m/t/3644173
by Eric Rimbey
Wolfram Community, STAFF PICKS, February 23, 2026
https://community.wolfram.com/groups/-/m/t/3644173