Control of a Two-Tank Blending System
Authors: Housam Binous and Ahmed Bellagi
Control of a Two-Tank Blending System
Authors: Housam Binous and Ahmed Bellagi
Authors: Housam Binous and Ahmed Bellagi
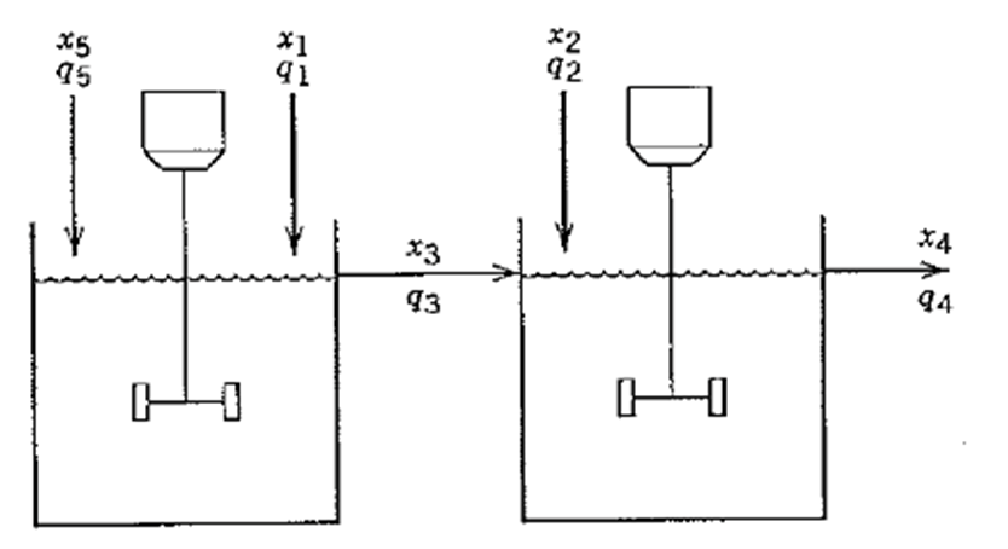
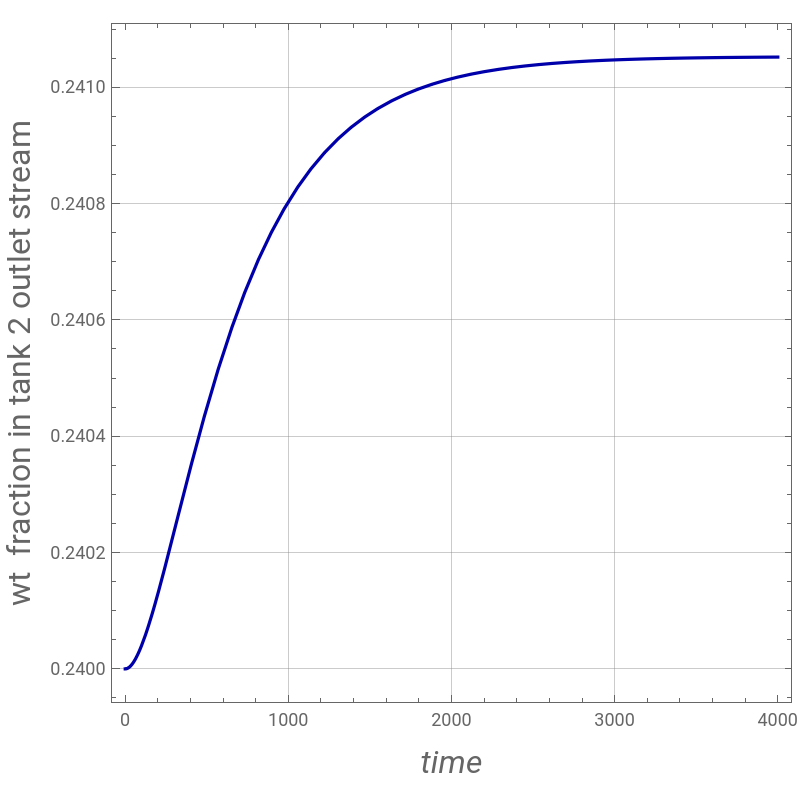
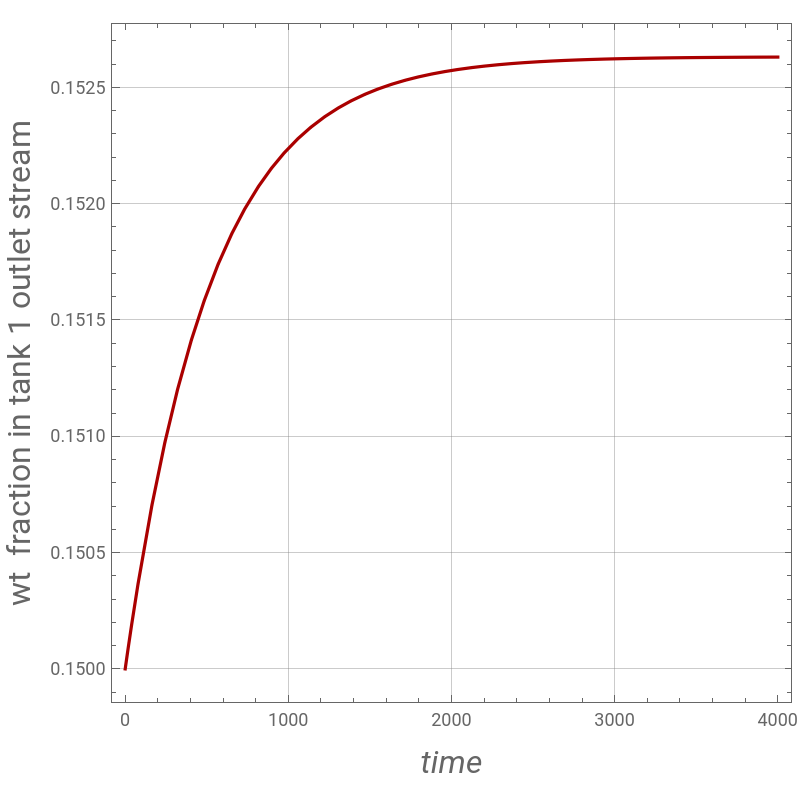
Figure below shows a sketch of a two-tank blending system.Total material balance is :Partial material balance is :where x is the weight fraction of component A. We assume the system is dilute. Hence, ρ ≈ constant.We assume =0 and =0 (i.e. tank volumes : V1 and V2 are kept constant by using an overflow line) then and q4=q3+q2.We also assume that the transmitters and control valves have negligible dynamics. Here, we propose to control the weight fraction of component A in the blender outlet stream, 4, by manipulating the mass flow rate of stream 2 (labeled q2).. Given: V1=V2=1 m3, x1=0.1, x2=0.3, x5=0.2, q1=1, q2=3, q5=1, q2n=3, ρ=1000. We suppose that the mass flow rate of stream 1, q1, is decreased to 0.9 at t=0.For each one of the scenarios below, we plot the outlet weight fraction and flow rate versus time.1. there is no control action.2. A P-controller is used to control the weight fraction of the outlet steam of tank 2. Controller gain is Kc = 100. =0.24wt %.3. A PI-controller is used to control the the weight fraction of the outlet steam of tank 2. Controller gain is Kc = 10 and the reset time is τI = 2. 4. If qs1 is kept equal to 1 at all times and the set point is fixed equal to 0.27 at t=0. A PI-controller is used to control the composition of the outlet stream of tank 2. Controller gain is Kc = 10 and the reset time is τI = 5.Reference:[1] D. E. Seborg, T. F. Edgar, D. A. Mellichamp, and F. J. Doyle III, Process Dynamics and Control, 4th ed., New York: Wiley, 2017.
ρA1=ρ==q1+q5-q3
h1
t
V1
t
m1
t
ρA2=ρ==q3+q2-q4
h2
t
V2
t
m2
t
ρV1=q1x1+q5x5-q3x3
x3
t
ρV2=q3x3+q2x2-q4x4
x4
t
V1
t
V1
t
q3=q1+q5
x
q2=q2n-e(t)+e(t)twithe(t)=-x4(t)
K
c
1
τ
I
x
sp
x
sp
Open loop response or no control action
In[]:=
ss=Flatten@NSolve[{q1x1+q5x5q3x3,q3q1+q5,q2x2+q3x3q4x4,q4q3+q2},{x4,x3,q3,q4}]
Out[]=
x4,x3,q3q1+q5,q4q1+q2+q5
q1x1+q2x2+q5x5
q1+q2+q5
q1x1+q5x5
q1+q5
In[]:=
x1=0.1;x2=0.3;x5=0.2;
In[]:=
q1=1;q2=3;q5=1;
In[]:=
ss
Out[]=
{x40.24,x30.15,q32,q45}
In[]:=
rho=1000;V=1;
In[]:=
q1=If[t<0,1,1×0.9]
Out[]=
If[t<0,1,1×0.9]
In[]:=
q3=2.;
In[]:=
sol=NDSolve[{rhoVx3'[t]q1x1+q5x5-(q1+q5)x3[t],x3[0]0.15,rhoVx4'[t]q2x2+q3x3[t]-(q2+q3)x4[t],x4[0]0.24},{x3,x4},{t,0,5000}]
Out[]=
x3InterpolatingFunction,x4InterpolatingFunction


In[]:=
Plot[x4[t]/.sol,{t,0,4000},PlotRangeAll,PlotStyleDarker@Blue,FrameTrue,GridLinesAutomatic,AspectRatio1,ImageSize400{1,1},FrameLabel{Style["time",16,Italic],Style["wt fraction in tank 2 outlet stream",16]}]
Out[]=
In[]:=
Plot[x3[t]/.sol,{t,0,4000},PlotRangeAll,PlotStyleDarker@Red,FrameTrue,GridLinesAutomatic,AspectRatio1,ImageSize400{1,1},FrameLabel{Style["time",16,Italic],Style["wt fraction in tank 1 outlet stream",16]}]
Out[]=
Closed loop response - proportional only control action
Closed loop response - proportional-integral control action
Closed loop response - proportional-integral control action - response to a set point change