A very very simple question: Compute and solve an Idle octopod Lagrangian with full numerical solutions (for 15s). But the caveat is that the spider to stand erect exclusively subsisting upon its Lagrangian. Moreover, program a rag-doll Spider: if the Lagrangian was replaced by a trivial one the spider should collapse dead on the ground (for 15s). For extra credit: program the spider in Attack Pose, start from Idle mode and smoothly but rapidly pose to attack. Well if you can program such a spider then you know your highschool physics really well!
Live Code Notebook:
https://www.wolframcloud.com/obj/ccn2/Published/Hamiltonian_things_part3_b1.0.nb
https://www.wolframcloud.com/obj/ccn2/Published/Hamiltonian_things_part3_b1.0.nb
In case of bugs in the code or the theory please make contact to fix ASAP.
Keywords: Hamiltonian mechanics, Lagrangian mechanics, Poisson bracket, Lagrangian linear operator, Octopod.
Software
Software
Release: β1.0
Scripts: Symbolic computations performed in Wolfram Mathematica 15.0 .
Notebook:
https://www.wolframcloud.com/obj/ccn2/Published/Hamiltonian_things_par1.nb
Support: Contact the author for additional code, bugs, correction in maths and algebraic/mathematical mistakes or invalid inferences.
Nomenclature: Most functions and most identifiers start with lower case letters, all native vendor identifiers start with upper case.
No Packaging: There is no software engineering applied to the code here nor elsewhere in the author’s technical notes to reduce the difficulties and version mismatches in future. The eager readers can simply copy paste the code or download and run the notebook.
TODO:
1. Examples: more to much more legs
2. Examples: more to much more leg segments
3. Examples: Different lengths legs
4. Examples: myriad of legs layouts attached to the torsos
5. Compute the inertia and torque for elongated torsos and tails
6. Fix the incorrect rotary inertia
7. Examples: uneven distribution of masses
Notebook:
https://www.wolframcloud.com/obj/ccn2/Published/Hamiltonian_things_par1.nb
Support: Contact the author for additional code, bugs, correction in maths and algebraic/mathematical mistakes or invalid inferences.
Nomenclature: Most functions and most identifiers start with lower case letters, all native vendor identifiers start with upper case.
No Packaging: There is no software engineering applied to the code here nor elsewhere in the author’s technical notes to reduce the difficulties and version mismatches in future. The eager readers can simply copy paste the code or download and run the notebook.
TODO:
1. Examples: more to much more legs
2. Examples: more to much more leg segments
3. Examples: Different lengths legs
4. Examples: myriad of legs layouts attached to the torsos
5. Compute the inertia and torque for elongated torsos and tails
6. Fix the incorrect rotary inertia
7. Examples: uneven distribution of masses
© 2012-Present CCN StudiosCreative Commons Attribution-NonCommercial-ShareAlike 4.0
1. ℋsynth Overview
1. ℋsynth Overview
ℋsynth stands for Hamiltonian Synthesizer is a unique symbolic computing cloud software which serves as a multi-function symbolic calculator for the calculi of Lagrange, Hamilton and Poisson insofar as variational calculus of different physics mechanics are concerned. See [1 - 4] for terrific details and sample solutions for fairly difficult systems.
synthesizer: it is a software that constructs actual functioning operating algebraic formal system, in ℋsynth case symbol spaces, functional spaces, operator spaces and transformation spaces which comprise the modern mechanics theories.
functional spaces: spaces of possibly or even most often undefined functions nonetheless existing functions which can serve as variables and symbols as well.
symbol spaces:,,,,,ℊ as examples parametrized as indexed symbols and reserved as singleton tokens immutable symbols. The term immutable means for example and are thought to be independent of each other insofar as differentiation operators are concerned and different than ! Even more fantastic ℋsynth distinguishes between
transformation spaces: Invariant transformations, Legendre transformation between Lagrangian and Hamiltonian mechanics, Canonical transformations to name a few
synthesizer: it is a software that constructs actual functioning operating algebraic formal system, in ℋsynth case symbol spaces, functional spaces, operator spaces and transformation spaces which comprise the modern mechanics theories.
functional spaces: spaces of possibly or even most often undefined functions nonetheless existing functions which can serve as variables and symbols as well.
symbol spaces:
i
i
i
i
i
i
transformation spaces: Invariant transformations, Legendre transformation between Lagrangian and Hamiltonian mechanics, Canonical transformations to name a few
Polynomial Time Complexity
Polynomial Time Complexity
1.1 Theorem: The time complexity of ℋsynth[ ] system is polynomial where is the number of objects in the mechanical system and the dimension. Proof: is the count for the generalized coordinates of the Lagrangian in theory + time. First, is the count for the dot-symbols called momenta, second the count for the Lagrange linear operator family is also by the definition =- where is the generalized coordinate equivalent to position and its corresponding momenta . Therefore, dot-symbols are required to be Term Rewriting by terms which bring the count to the polynomial . However, during the current implementation of ℋsynth it became patently clear that each term of the Term Rewiring being a function e.g. (,...,,,...,), if we linearize that read/write IO as steps, then the total sum for the complexity tallies up to (×). The third degree polynomial in both initial counters and is prohibitively expensive for direct applications such as polymer dynamics simulations dealing with tens of thousands of atoms or molecules (goal is millions). However most readers reader would not comprehend the polynomial time’s gargantuan magnitude until actually running code and attempting to compute a large Hamiltonian or Lagrangian system. 1.2 Theorem: The space complexity of ℋsynth[ ] system is polynomial where is the number of objects in the mechanical system and the dimension. Proof. Similar combinatorial arguments as to the Theorem 1.1.
O(×)
3
3
2×+1
×
Λ
α
×
Λ
α
t
∂
∂
p
i
∂
∂p
p
p
×
×
2
(×)
r
α
p
1
p
r
1
r
2
2
(×)
O(×)
2
2
Initialization
Initialization
In[]:=
(*TODObettersimplerinterface*)Notation`AutoLoadNotationPalette=False;Needs["Notation`"];ClearNotations[];CloudGet["https://wolfr.am/1xEVtfjBx"];ℋinit[];
version: β6.1
2. ℋsynth or Hsynth
2. ℋsynth or Hsynth
2.1 Organization of Generalized Coordinates and corresponding Momenta
2.1 Organization of Generalized Coordinates and corresponding Momenta
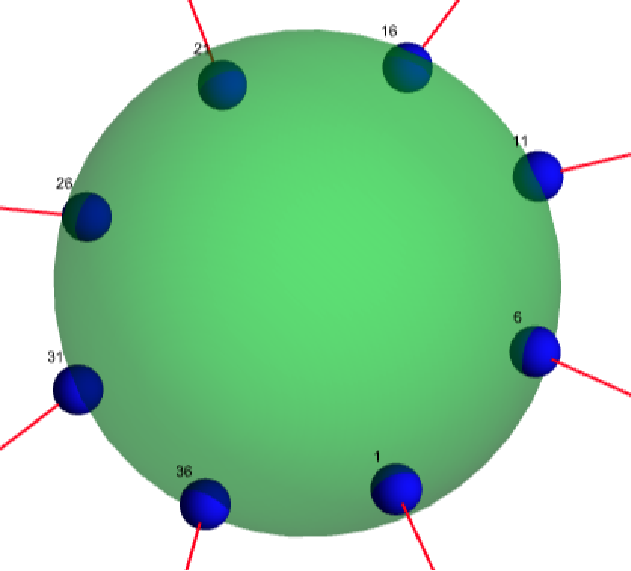
Summary● The current spider has 8 legs ● Legs are laid out around a circle● Each leg has 4 segments thus 5 joints/vertices● Joints are point masses with constant mass● Distance between the joints is fixed though time but possibly variable between the joints and legs● The neighboring segments are connect with springs of constant coefficients ● θ-positions: are angles between the connected segments to a joint e.g. is the angle between the segment 1 of leg 1 and the segment 2 of leg 1 sharing joint 2. ● Z-positions: are z values for the 8 first joints/vertices of the 8 legs.● momenta: these are rotary momentum for each joint/vertex. Note that, in this case we do not directly access them.● generalized coordinates: and for time. ● dots: These are also a part of the generalized coordinate system and they are abstractions of derivatives with regards to time (or any symbol and concept the theory requires) and yet it is an atomic symbol by itself meaning it does not implicitly participate in the derivative rules. These identifications as derivatives need to be force computed. This innovation of turning off and delaying the actions of an algebra on a symbol and later force to compute it again, to the best of my knowledge is Lagrange’s. In symbolic computation we call this form of evaluation as delayed evaluation. Mr. Lagrange indeed innovated the delayed evaluation into the mathematics of his time which revolutionized all calculi for centuries to come.
θ
2
{,,...,,}
θ
1
θ
2
θ
39
θ
40
{,,,,,,,}
θ
33
θ
34
θ
35
θ
36
θ
37
θ
38
θ
39
θ
40
{,,...,,}
p
1
p
2
p
39
p
40
{,,...,,,,,...,,,}
θ
1
θ
2
θ
39
θ
40
p
1
p
2
p
39
p
40
,,...,,,,,...,,
θ
1
θ
2
θ
39
θ
40
p
1
p
2
p
39
p
40
3. Octopod Lagrangian System
3. Octopod Lagrangian System
3.1 System Symbolics Setup
3.1 System Symbolics Setup
In[]:=
ℋinit[];(*numberoflegs*)n=8;(*numberofsegments*)segements=4;(*numnberofjoints/vertices*)=(segements+0)*n+n;(*Dimensionofeachsinglepositionormomentominthiscase1Dspringmodel*)=1;(*convinientcountofallpositionsandmomentasymbols*)2=(segements+1)*n*;(*Symbolicnomenclatureofgeneralizedvariables,θforpositions,pformomenta*)res=ℋsynth["θp"];(*evilnecessitytoassignsymbolthevalueoftheLagrangian*)∈ℒ;
3.2 Leg1 Configuration
3.2 Leg1 Configuration
4. Lagrangian
4. Lagrangian
4.1 Time Varying External Forces
Two external forces smoothly raise the entire leg1 and leg8 with a delay for the latter and maintain the lags to remain raised.
5. Solve Lagrangian Linear Operator Λ
5. Solve Lagrangian Linear Operator Λ
5.1 Idle
5.1 Idle
θ Configuration Space
θ Configuration Space
5.2 Helper Functions
5.2 Helper Functions
5.6 Animate the Equations of Motion
5.6 Animate the Equations of Motion
5.7 Animate
5.7 Animate
6. Attack Pose
6. Attack Pose
θ Configuration Space
θ Configuration Space
6.1 Animate the Equations of Motion
6.1 Animate the Equations of Motion
6.2 Animate
6.2 Animate
7. Rag-doll
7. Rag-doll
θ Configuration Space
θ Configuration Space
7.1 Animate the Equations of Motion
7.1 Animate the Equations of Motion
7.2 Animate
7.2 Animate
References
[1] Douglas Cline, VARIATIONAL PRINCIPLES IN CLASSICAL MECHANICS, University of Rochester
[2] Derivating things: Construction of the Generalized functions and computing their derivatives (fully coded) Part1-ν2.1
DOI: 10.13140/RG.2.2.30726.23364. https://www.researchgate.net/publication/395806943_Derivating_things_Construction_of_the_Generalized_functions_and_computing_their_derivatives_fully_coded_Part1-n21
DOI: 10.13140/RG.2.2.30726.23364. https://www.researchgate.net/publication/395806943_Derivating_things_Construction_of_the_Generalized_functions_and_computing_their_derivatives_fully_coded_Part1-n21
[3] Hamiltonian, Lagrangian things Part1-β2.1. DOI: 10.13140/RG.2.2.27370.79047
https://www.researchgate.net/publication/395012799_Hamiltonian_Lagrangian_things_Part1-b21
https://www.researchgate.net/publication/395012799_Hamiltonian_Lagrangian_things_Part1-b21
[4] Hamiltonian, Lagrangian things: Graph Lagrangian for CO2 and Benzene to compute vibrational spectra (fully coded) Part2-β2.1
DOI: 10.13140/RG.2.2.13949.01766. https://www.researchgate.net/publication/395339700_Hamiltonian_Lagrangian_things_Graph_Lagrangian_for_CO2_and_Benzene_to_compute_vibrational_spectra_fully_coded_Part2-b21
DOI: 10.13140/RG.2.2.13949.01766. https://www.researchgate.net/publication/395339700_Hamiltonian_Lagrangian_things_Graph_Lagrangian_for_CO2_and_Benzene_to_compute_vibrational_spectra_fully_coded_Part2-b21
CITE THIS NOTEBOOK
CITE THIS NOTEBOOK
Teapod spider: Hamiltonian, Lagrangian things
by Dara Shayda
Wolfram Community, STAFF PICKS, July 8, 2026
https://community.wolfram.com/groups/-/m/t/3746334
by Dara Shayda
Wolfram Community, STAFF PICKS, July 8, 2026
https://community.wolfram.com/groups/-/m/t/3746334